CERTUS-BD992
Model / article: CERTUS-BD992
CERTUS-BD992 is listed by Advanced Navigation in GNSS-aided inertial navigation. Published model data includes Product mass: 0.28 kg; Communication interface: Ethernet, RS232/RS422, CAN. See the specification table for operating conditions and source evidence.
Dual-antenna navigation modules for UGVs and robotics. Receiver and enclosure variants are separate. Fused navigation accuracy remains unnormalized because the v2.12 navigation table assumes X20P; no certification or safety rating inferred.
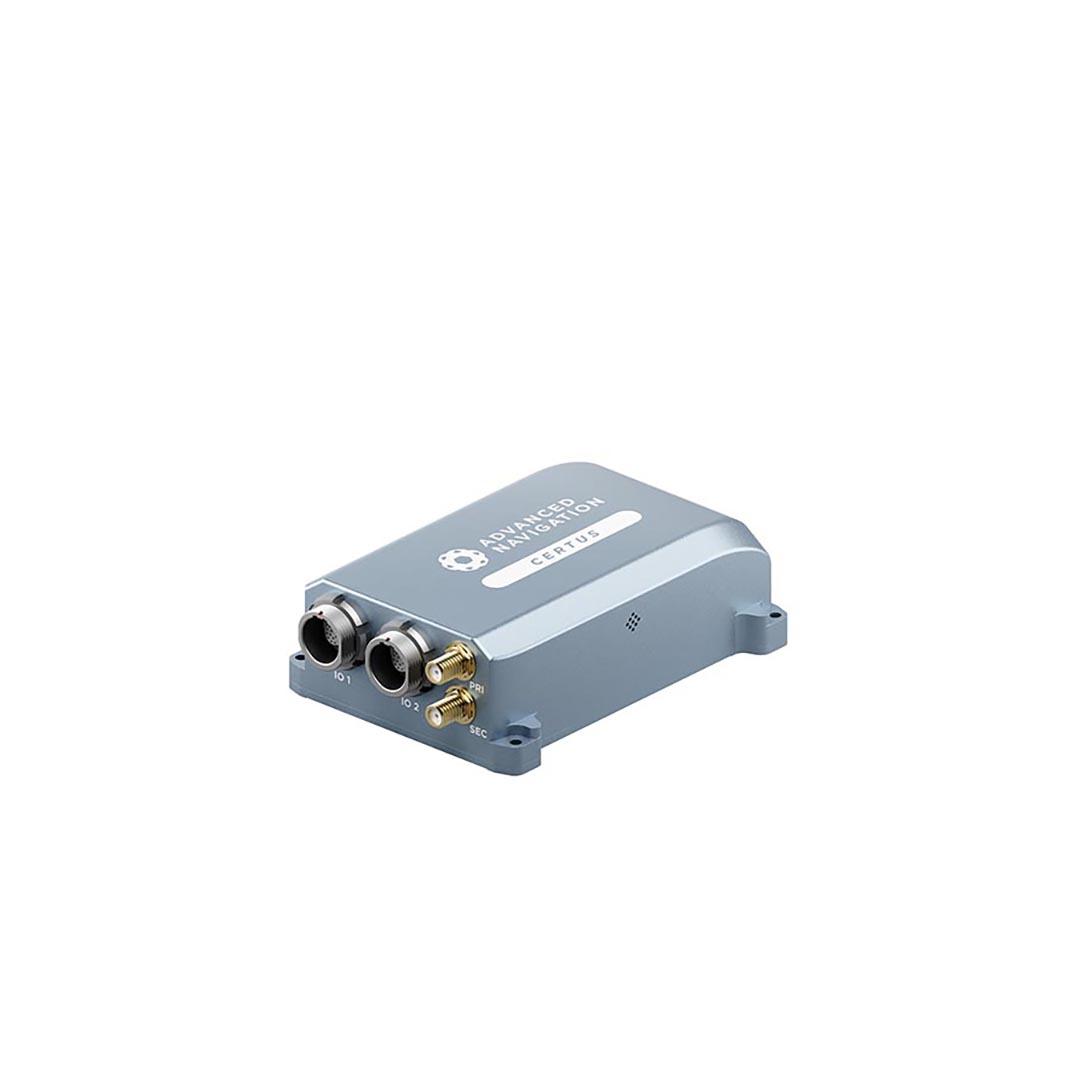
Product overview
- Manufacturer / supplier
- Advanced Navigation
- Series
- Certus GNSS-aided inertial navigation
- Component type
- GNSS-aided inertial navigation
- Source
- Open published source
Published pricing
No verified public price indexed for this model. Contact PartMeld for a supplier inquiry.
Published specifications
Values are shown as published. Conditions, rating basis and source evidence apply to each value.
Latest source observation: . Observation dates record evidence collection, not supplier re-verification.
| Specification | Published value | Conditions and source |
|---|---|---|
| Communication interfaceModel-level statement | Ethernet, RS232/RS422, CAN | rule validated Source evidenceCommunication interfaces: Ethernet, RS232/RS422, CAN CERTUS-BD992 / v2.12 PDF p.37 / Communication interfaces |
| DimensionsModel-level statement | 78 x 115 x 34 mm | rule validated Source evidenceDimensions: 78 x 115 x 34 mm CERTUS-BD992 / v2.12 PDF p.32 / Dimensions |
| Imu accel rangesModel-level statement | ±2, ±4, ±16 g | rule validated Operating conditions
Source evidenceSelectable acceleration ranges: ±2, ±4, ±16 g CERTUS-BD992 / v2.12 PDF p.28 / Selectable acceleration ranges |
| Imu gyro noiseModel-level statement | 0.004 deg/s/√Hz | rule validated Source evidenceGyroscope noise density: 0.004 deg/s/√Hz CERTUS-BD992 / v2.12 PDF p.29 / Gyroscope noise density |
| Imu gyro rangesModel-level statement | ±250, ±500, ±2000 deg/s | rule validated Operating conditions
Source evidenceSelectable angular rate ranges: ±250, ±500, ±2000 deg/s CERTUS-BD992 / v2.12 PDF p.28 / Selectable angular rate ranges |
| Product massModel-level statement | 0.28 kg | rule validated Operating conditions
Source evidenceWeight: 0.28 kg CERTUS-BD992 / v2.12 PDF p.32 / Weight |
| Navigation accel biasModel-level statement | 20 µg | rule validated Operating conditions
Source evidenceAccelerometer bias instability: 20 µg CERTUS-BD992 / v2.12 PDF p.28 / Accelerometer bias instability |
| Navigation accel noiseModel-level statement | 100 µg/√Hz | rule validated Source evidenceAccelerometer noise density: 100 µg/√Hz CERTUS-BD992 / v2.12 PDF p.29 / Accelerometer noise density |
| Navigation gyro biasModel-level statement | 3 deg/h | rule validated Operating conditions
Source evidenceGyroscope bias instability: 3 deg/h CERTUS-BD992 / v2.12 PDF p.28 / Gyroscope bias instability |
| Navigation powerModel-level statement | 2.64 W | rule validated Operating conditions
Source evidenceTypical power consumption: 2.64 W CERTUS-BD992 / v2.12 PDF p.38 / Typical power consumption |
| Navigation protocolModel-level statement | AN Packet Protocol; NMEA 0183 | rule validated Source evidenceCommunication protocols: AN Packet Protocol; NMEA 0183 CERTUS-BD992 / v2.12 PDF p.37 / Communication protocols |
| Navigation receiverModel-level statement | Trimble BD992 | rule validated Operating conditions
Source evidenceGNSS receiver: Trimble BD992 CERTUS-BD992 / v2.12 PDF p.25 / GNSS receiver |
| Navigation sensor bandwidthModel-level statement | 400 Hz | rule validated Operating conditions
Source evidenceAccelerometer and gyro bandwidth: 400 Hz CERTUS-BD992 / v2.12 PDF p.29 / Accelerometer and gyro bandwidth |
| Operating temperature rangeModel-level statement | -40 to 85 °C | rule validated Source evidenceOperating and storage temperature: -40 to 85 °C CERTUS-BD992 / v2.12 PDF p.33 / Operating and storage temperature |
| Supply voltage rangeModel-level statement | 9 to 36 V | rule validated Operating conditions
Source evidenceOperating supply voltage: 9 to 36 V CERTUS-BD992 / v2.12 PDF p.38 / Operating supply voltage |
Technical documents and resources
Confirm the exact configuration, price, availability and operating conditions with the supplier before ordering.