Advanced / 632-91181
Model / article: V20-RO-A3-R-M-M2-AL-P1-40
Advanced / 632-91181 is listed by SensoPart in Robot vision. Published model data includes Communication interface: TCP/IP, Profinet, EtherNet/IP, sFTP, SMB, FTP, Service Port; Overall length: 45.0. See the specification table for operating conditions and source evidence.
Monochrome 2D robot-guidance vision sensor with integrated distance measurement; Professional variant.
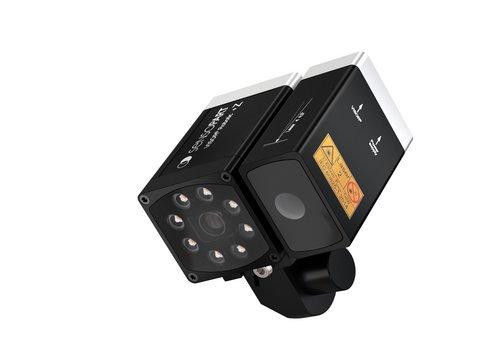
Product overview
- Manufacturer / supplier
- SensoPart
- Series
- VISOR Robotic +Z
- Component type
- Robot vision
- Source
- Open published source
Published pricing
No verified public price indexed for this model. Contact PartMeld for a supplier inquiry.
Published specifications
Values are shown as published. Conditions, rating basis and source evidence apply to each value.
Latest source observation: . Observation dates record evidence collection, not supplier re-verification.
| Specification | Published value | Conditions and source |
|---|---|---|
| Communication interfaceModel-level statement | TCP/IP, Profinet, EtherNet/IP, sFTP, SMB, FTP, Service Port | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Network protocol: TCP/IP, Profinet, EtherNet/IP, sFTP, SMB, FTP, Service Port attributeTable[2]/tbody/tr[1] |
| Overall lengthModel-level statement | 45.0 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Length [mm]: 45.0 attributeTable[4]/tbody/tr[2] |
| Sensor connectorModel-level statement | Connection name: LAN; - Number of pins: 4; - Coding: D; - Thread: M12x1; - Material: Metal; - Type: Socket | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Connection name: Connection name: LAN; - Number of pins: 4; - Coding: D; - Thread: M12x1; - Material: Metal; - Type: Socket attributeTable[4]/tbody/tr[13..18] |
| Sensor connectorModel-level statement | Connection name: Supply; - Number of pins: 12; - Coding: A; - Thread: M12x1; - Material: Metal; - Type: Plug | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Connection name: Connection name: Supply; - Number of pins: 12; - Coding: A; - Thread: M12x1; - Material: Metal; - Type: Plug attributeTable[4]/tbody/tr[7..12] |
| Sensor current consumptionModel-level statement | 350Rating: typical | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Typical current draw [mA]: 350 attributeTable[3]/tbody/tr[4] |
| Sensor materialModel-level statement | Aluminum (cast) | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Housing material: Aluminum (cast) attributeTable[4]/tbody/tr[6] |
| Sensor materialModel-level statement | PMMA | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Front panel material: PMMA attributeTable[4]/tbody/tr[5] |
| Sensor supply voltageModel-level statement | 18 ... 30 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Operating voltage UB [V DC]: 18 ... 30 attributeTable[3]/tbody/tr[3] |
| Vision additional functionsModel-level statement | Archiving, Image transmission, individual overlays, Multiple image acquisition, Multiple detection for contour and pattern matching detector, Multiple detection for detector contour (3D), Job checksum | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Additional functions: Archiving, Image transmission, individual overlays, Multiple image acquisition, Multiple detection for contour and pattern matching detector, Multiple detection for detector contour (3D), Job checksum attributeTable[2]/tbody/tr[10] |
| Vision calibration modesModel-level statement | Board (measurement), Board (robotics), Scaling (measurement), Point pair list (robotics) | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Calibration: Board (measurement), Board (robotics), Scaling (measurement), Point pair list (robotics) attributeTable[2]/tbody/tr[8] |
| Vision distance spot sizeModel-level statement | 2 x 5 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Light spot size [mm]: 2 x 5 attributeTable[1]/tbody/tr[3] |
| Vision ethernet rateModel-level statement | 100 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Ethernet transmission rate [Mbit/s]: 100 attributeTable[3]/tbody/tr[20] |
| Vision focal lengthModel-level statement | 12.0 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Focal length [mm]: 12.0 attributeTable[1]/tbody/tr[18] |
| Vision focus driveModel-level statement | Motorized | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Focus drive: Motorized attributeTable[1]/tbody/tr[22] |
| Vision image chip technologyModel-level statement | CMOS | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Imaging chip technology: CMOS attributeTable[1]/tbody/tr[14] |
| Vision image resolutionModel-level statement | 1440 x 1080 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Number of pixels (H x V) [px]: 1440 x 1080 attributeTable[1]/tbody/tr[13] |
| Vision ingress protectionModel-level statement | IP 65, IP 67 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Protection class: IP 65, IP 67 attributeTable[4]/tbody/tr[24] |
| Vision max detectorsModel-level statement | 255 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Max. number of detectors: 255 attributeTable[2]/tbody/tr[4] |
| Vision max jobsModel-level statement | 255 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Max. number of jobs: 255 attributeTable[2]/tbody/tr[3] |
| Vision minimum field of viewModel-level statement | 10 x 8 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Min. field of view (X x Y) [mm]: 10 x 8 attributeTable[1]/tbody/tr[24] |
| Vision opening angleModel-level statement | 24.0 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Opening angle [°]: 24.0 attributeTable[1]/tbody/tr[19] |
| Vision optical operating distanceModel-level statement | 25 ... 10,000 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Operating distance [mm]: 25 ... 10,000 attributeTable[1]/tbody/tr[17] |
| Vision pixel sizeModel-level statement | 3.45 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Pixel size [µm]: 3.45 attributeTable[1]/tbody/tr[15] |
| Vision robotic functionsModel-level statement | Gripper clearance check, Result offset, image coordinates, Result offset 2D, Result offset 3D | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Robotic functions: Gripper clearance check, Result offset, image coordinates, Result offset 2D, Result offset 3D attributeTable[2]/tbody/tr[9] |
| Vision storage temperatureModel-level statement | -20 ... 60 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Ambient temperature: storage [°C]: -20 ... 60 attributeTable[4]/tbody/tr[22] |
| Vision system typeModel-level statement | 2D vision-guided robotics with integrated distance measurement | rule validated Operating conditions
Source evidenceThe VISOR Robotic +Z combines the strengths of 2D vision-guided robotics with precise distance measurement for large working distances. VISOR Robotic +Z description |
| Vision warmup timeModel-level statement | 20 | rule validated Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Warm-up time [Min.]: 20 attributeTable[3]/tbody/tr[1] |
| Working distanceModel-level statement | 150 ... 2,500 | rule validated Operating conditions
Source evidenceV20-RO-A3-R-M-M2-AL-P1-40 [632-91181] | Working range [mm]: 150 ... 2,500 attributeTable[1]/tbody/tr[2] |
Technical documents and resources
Confirm the exact configuration, price, availability and operating conditions with the supplier before ordering.