Shadow Dexterous Hand
Model / article: Shadow Dexterous Hand
Shadow Dexterous Hand is listed by Shadow Robot in Dexterous robotic hands. Published model data includes Product mass: 4.3 kg; Motor type: DC Smart Motor nodes. See the specification table for operating conditions and source evidence.
Self-contained humanoid hand and forearm. Actuation, sensing and communication are integrated; individual joint torque output is not published as a comparable model specification.
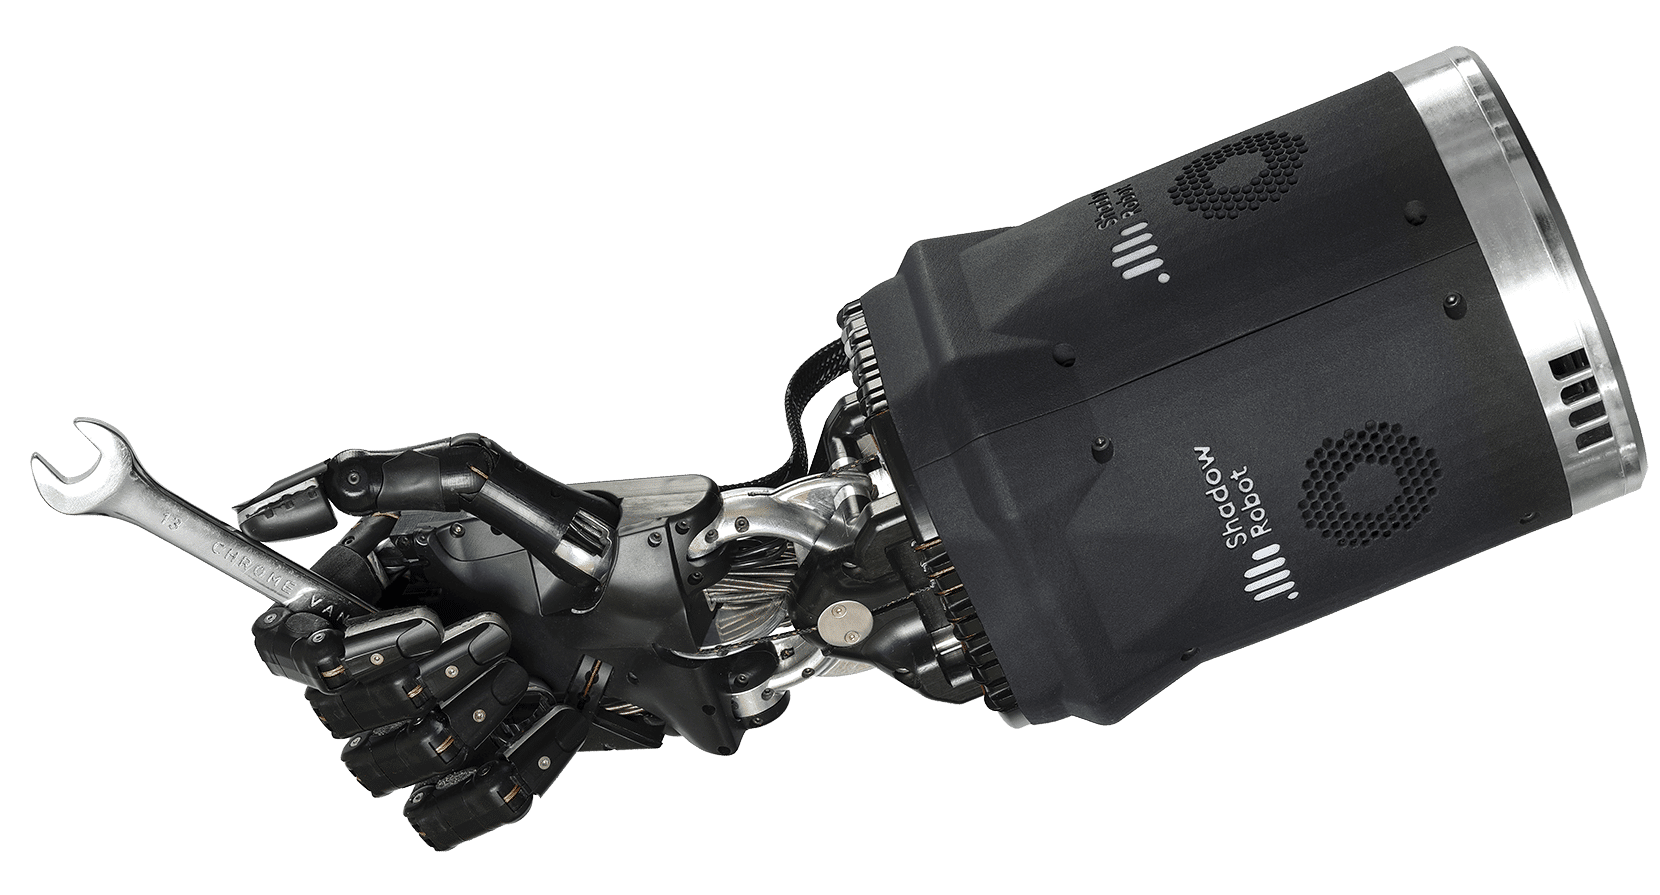
Product overview
- Manufacturer / supplier
- Shadow Robot
- Series
- Dexterous robotic hands
- Component type
- Dexterous robotic hands
- Source
- Open published source
Published pricing
No verified public price indexed for this model. Contact PartMeld for a supplier inquiry.
Published specifications
Values are shown as published. Conditions, rating basis and source evidence apply to each value.
Latest source observation: . Observation dates record evidence collection, not supplier re-verification.
| Specification | Published value | Conditions and source |
|---|---|---|
| Gripper control interfaceModel-level statement | EtherCAT (100 Mbps), ROS | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Communication: EtherCAT (100 Mbps), ROS Shadow Dexterous Hand / source page 6 / Communication |
| Hand actuated dofModel-level statement | 20 | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Actuated degrees of freedom: 20 Shadow Dexterous Hand / source page 6 / Actuated degrees of freedom |
| Hand control rateModel-level statement | 1000 Hz | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Host control loop: 1000 Hz Shadow Dexterous Hand / source page 6 / Host control loop |
| Hand number of fingersModel-level statement | 5 | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Number of fingers: 5 Shadow Dexterous Hand / source page 6 / Number of fingers |
| Hand payloadModel-level statement | 4 kg | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Power-grasp payload: 4 kg Shadow Dexterous Hand / source page 6 / Power-grasp payload |
| Hand total jointsModel-level statement | 24 | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Total joints: 24 Shadow Dexterous Hand / source page 6 / Total joints |
| Product massModel-level statement | 4.3 kg | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Hand and forearm weight: 4.3 kg Shadow Dexterous Hand / source page 6 / Hand and forearm weight |
| Motor typeModel-level statement | DC Smart Motor nodes | rule validated Operating conditions
Source evidenceShadow Dexterous Hand | Actuation: DC Smart Motor nodes Shadow Dexterous Hand / source page 6 / Actuation |
Technical documents and resources
Confirm the exact configuration, price, availability and operating conditions with the supplier before ordering.