2F-140
Model / article: 2F-140
2F-140 is listed by Robotiq in Parallel & adaptive grippers. Published model data includes Product mass: 1.025 kg; Supply voltage range: 21.6 to 26.4 V. See the specification table for operating conditions and source evidence.
Adaptive industrial two-finger grippers. Mechanical specifications retain the manual coupling and fingertip conditions; payload requires application-specific assessment.
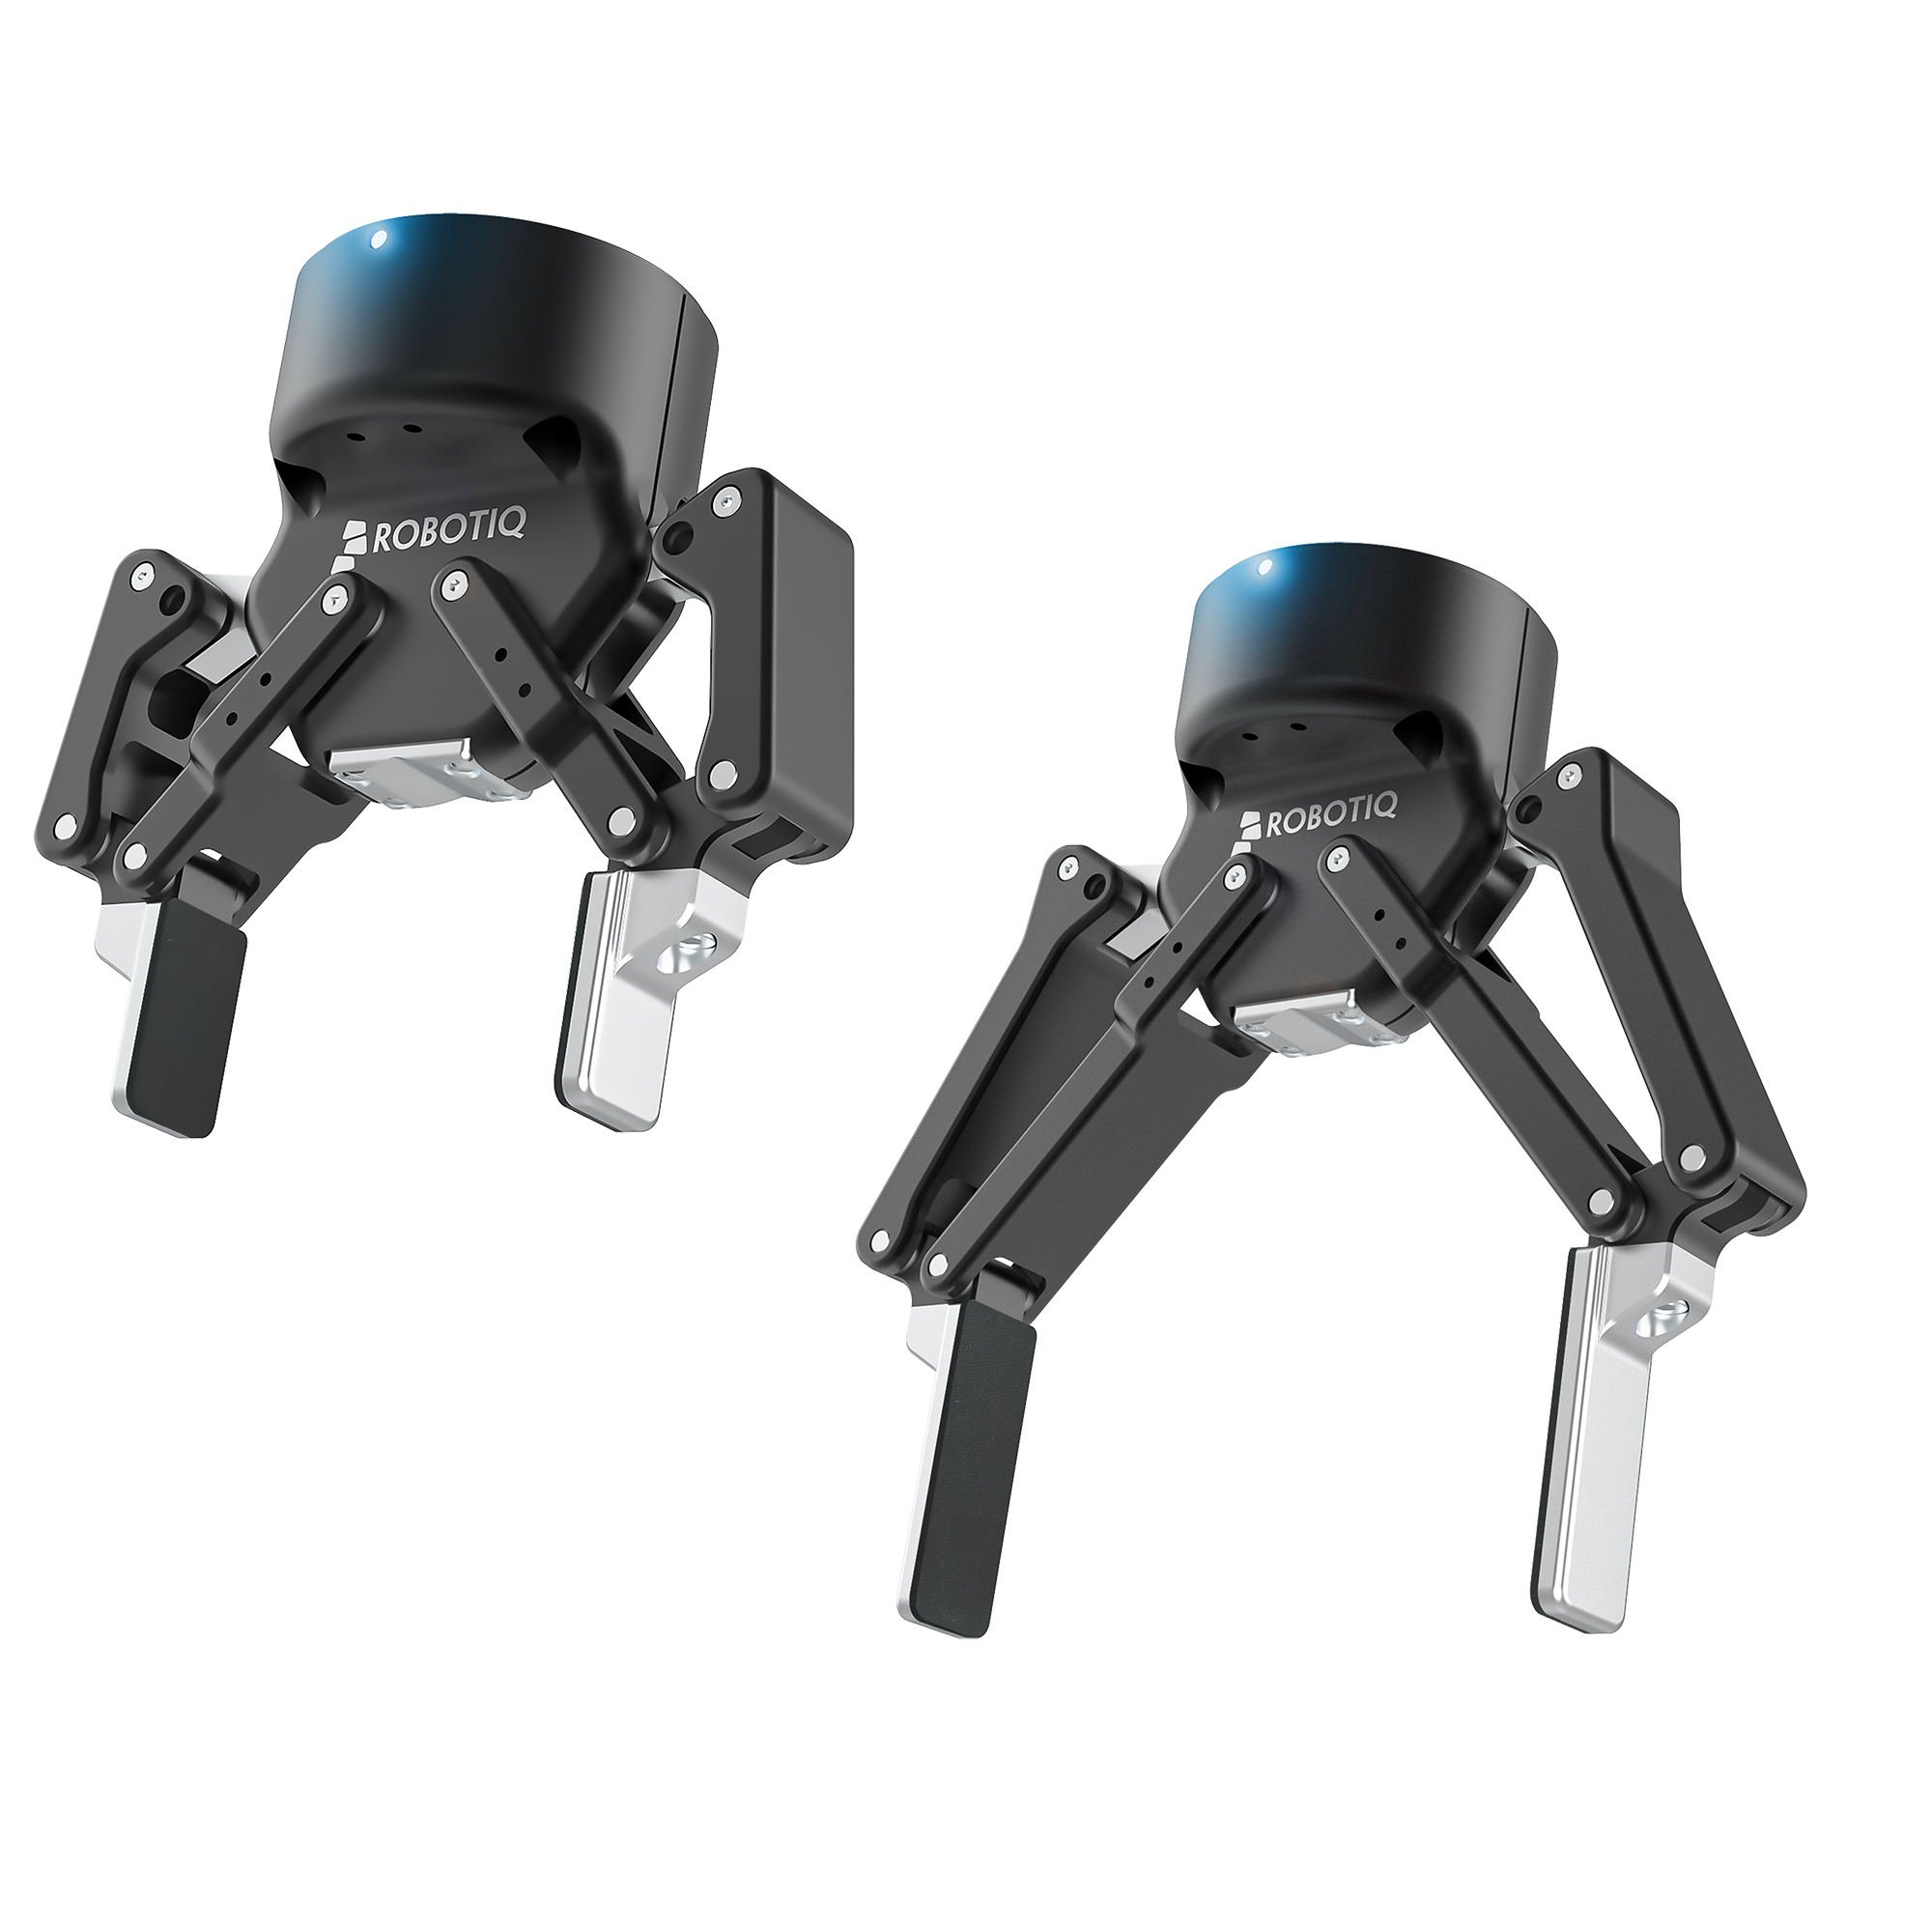
Product overview
- Manufacturer / supplier
- Robotiq
- Series
- 2F adaptive two-finger grippers
- Component type
- Parallel & adaptive grippers
- Source
- Open published source
Published pricing
No verified public price indexed for this model. Contact PartMeld for a supplier inquiry.
Published specifications
Values are shown as published. Conditions, rating basis and source evidence apply to each value.
Latest source observation: . Observation dates record evidence collection, not supplier re-verification.
| Specification | Published value | Conditions and source |
|---|---|---|
| Gripper closing speedModel-level statement | 30 to 250 mm/s | rule validated Operating conditions
Source evidence2F-140 | Finger speed: 30 to 250 mm/s 2F-140 / instruction manual p.119 / Finger speed |
| Gripper control interfaceModel-level statement | Modbus RTU over RS-485 | rule validated Source evidence2F-140 | Communication protocol: Modbus RTU over RS-485 2F-140 / instruction manual p.15 / Communication protocol |
| Gripper forceModel-level statement | 10 to 125 N | rule validated Operating conditions
Source evidence2F-140 | Grasp force: 10 to 125 N 2F-140 / instruction manual p.119 / Grasp force |
| Gripper payloadModel-level statement | 2.5 kg | rule validated Operating conditions
Source evidence2F-140 | Maximum payload by grasp type: 2.5 kg 2F-140 / instruction manual p.122 / Maximum payload by grasp type |
| Gripper repetition accuracyModel-level statement | 0.08 mm | rule validated Operating conditions
Source evidence2F-140 | Position repeatability: 0.08 mm 2F-140 / instruction manual p.119 / Position repeatability |
| Gripper strokeModel-level statement | 140 mm | rule validated Operating conditions
Source evidence2F-140 | Gripper opening: 140 mm 2F-140 / instruction manual p.119 / Gripper opening |
| Product massModel-level statement | 1.025 kg | rule validated Operating conditions
Source evidence2F-140 | Weight: 1.025 kg 2F-140 / instruction manual p.119 / Weight |
| Supply voltage rangeModel-level statement | 21.6 to 26.4 V | rule validated Operating conditions
Source evidence2F-140 | Operating supply voltage: 21.6 to 26.4 V 2F-140 / instruction manual p.127 / Operating supply voltage |
Technical documents and resources
Confirm the exact configuration, price, availability and operating conditions with the supplier before ordering.