RPLIDAR S2E
Model / article: S2E
RPLIDAR S2E is listed by SLAMTEC in Robot LiDAR. Published model data includes Nominal supply voltage: 12V; Operating temperature range: -10℃-50℃. See the specification table for operating conditions and source evidence.
Published S2 product models; pitch-angle ordering-code variants are not separately indexed.
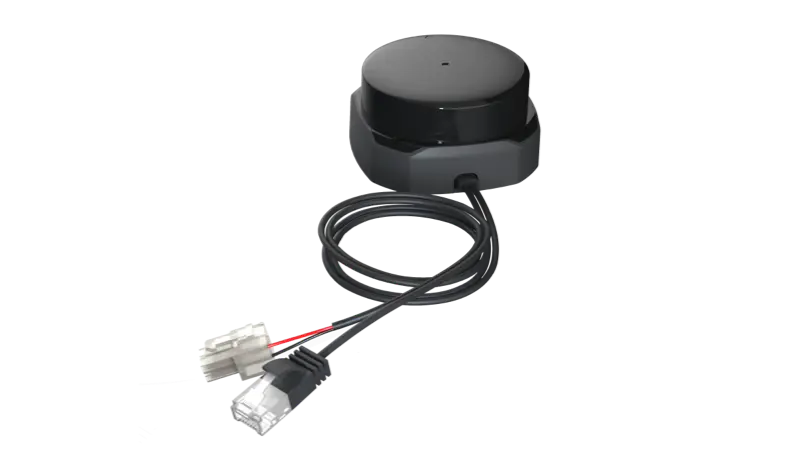
Product overview
- Manufacturer / supplier
- SLAMTEC
- Series
- RPLIDAR S2
- Component type
- Robot LiDAR
- Source
- Open published source
Published pricing
No verified public price indexed for this model. Contact PartMeld for a supplier inquiry.
Published specifications
Values are shown as published. Conditions, rating basis and source evidence apply to each value.
Latest source observation: . Observation dates record evidence collection, not supplier re-verification.
| Specification | Published value | Conditions and source |
|---|---|---|
| Lidar angular resolutionModel-level statement | 0.1125°Rating: typical | rule validated Operating conditions
Source evidenceS2E | Angular Resolution: 0.1125° table.a3-parameter-table column 4 |
| Lidar blind rangeModel-level statement | 0.05m | rule validated Source evidenceS2E | Blind Range: 0.05m table.a3-parameter-table column 4 |
| Lidar distance accuracyModel-level statement | ±30mm | rule validated Operating conditions
Source evidenceS2E | Accuracy: ±30mm table.a3-parameter-table column 4 |
| Lidar distance resolutionModel-level statement | 13mm | rule validated Source evidenceS2E | Distance Resolution: 13mm table.a3-parameter-table column 4 |
| Lidar frame rateModel-level statement | 10HzRating: typical | rule validated Operating conditions
Source evidenceS2E | Scan Rate: 10Hz table.a3-parameter-table column 4 |
| Lidar point rateModel-level statement | 32000 times per secord | rule validated Source evidenceS2E | Sample Rate: 32000 times per secord table.a3-parameter-table column 4 |
| Lidar powerModel-level statement | > 2W | rule validated Operating conditions
Source evidenceS2E | Power Consumption: > 2W table.a3-parameter-table column 4 |
| Lidar range 10 reflectivityModel-level statement | 0.05-10m(10% reflection)Rating: maximum | rule validated Operating conditions
Source evidenceS2E | Distance Range: 0.05-10m(10% reflection) table.a3-parameter-table column 4 |
| Lidar range 90 reflectivityModel-level statement | 0.05-30m(90% reflection)Rating: maximum | rule validated Operating conditions
Source evidenceS2E | Distance Range: 0.05-30m(90% reflection) table.a3-parameter-table column 4 |
| Lidar scan flatnessModel-level statement | ±1.5° | rule validated Operating conditions
Source evidenceS2E | Scan Field Flatness: ±1.5° table.a3-parameter-table column 4 |
| Nominal supply voltageModel-level statement | 12V | rule validated Source evidenceS2E | System Voltage: 12V table.a3-parameter-table column 4 |
| Operating temperature rangeModel-level statement | -10℃-50℃ | rule validated Source evidenceS2E | Temperature Range: -10℃-50℃ table.a3-parameter-table column 4 |
| Sensor interfaceModel-level statement | Ethernet UDP(10/100M) | rule validated Source evidenceS2E | Communication Interface: Ethernet UDP(10/100M) table.a3-parameter-table column 4 |
| Vision ingress protectionModel-level statement | IP65 | rule validated Source evidenceS2E | Proof Level: IP65 table.a3-parameter-table column 4 |
Technical documents and resources
Confirm the exact configuration, price, availability and operating conditions with the supplier before ordering.